Hackachusetts 2026 · team of 3 · robots, simulation and autopilot loop mine
A drone above the water and an ROV below it, inspecting a real Boston bridge
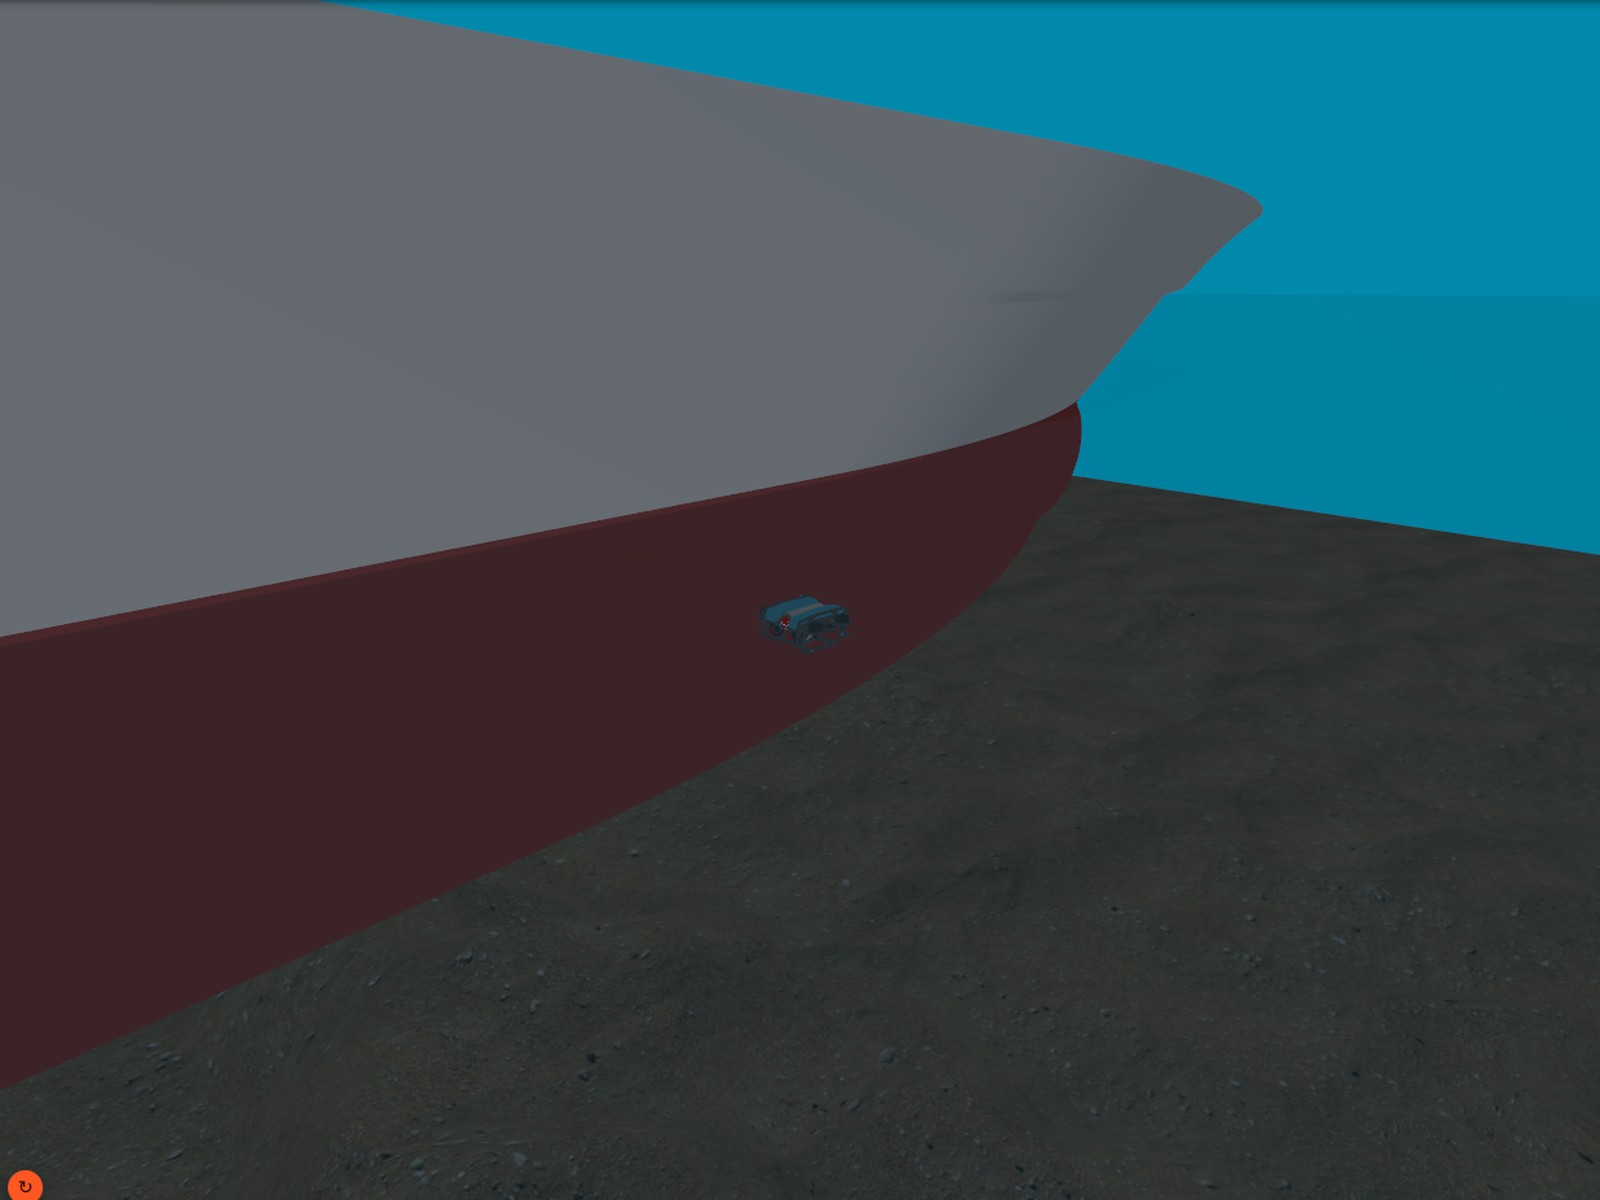
Real ArduCopter and ArduSub firmware fly a drone and an ROV through an Isaac Sim rebuild of the Charles River Dam crossing. Every waterline defect the drone flags, the ROV dives to inspect.
- ROV nav error, GPS off
- ≤ 0.60 m
- points, lidar above + sonar below
- 4.54 M
- flagged defects inspected
- 4 / 4
Details, my part and the stack
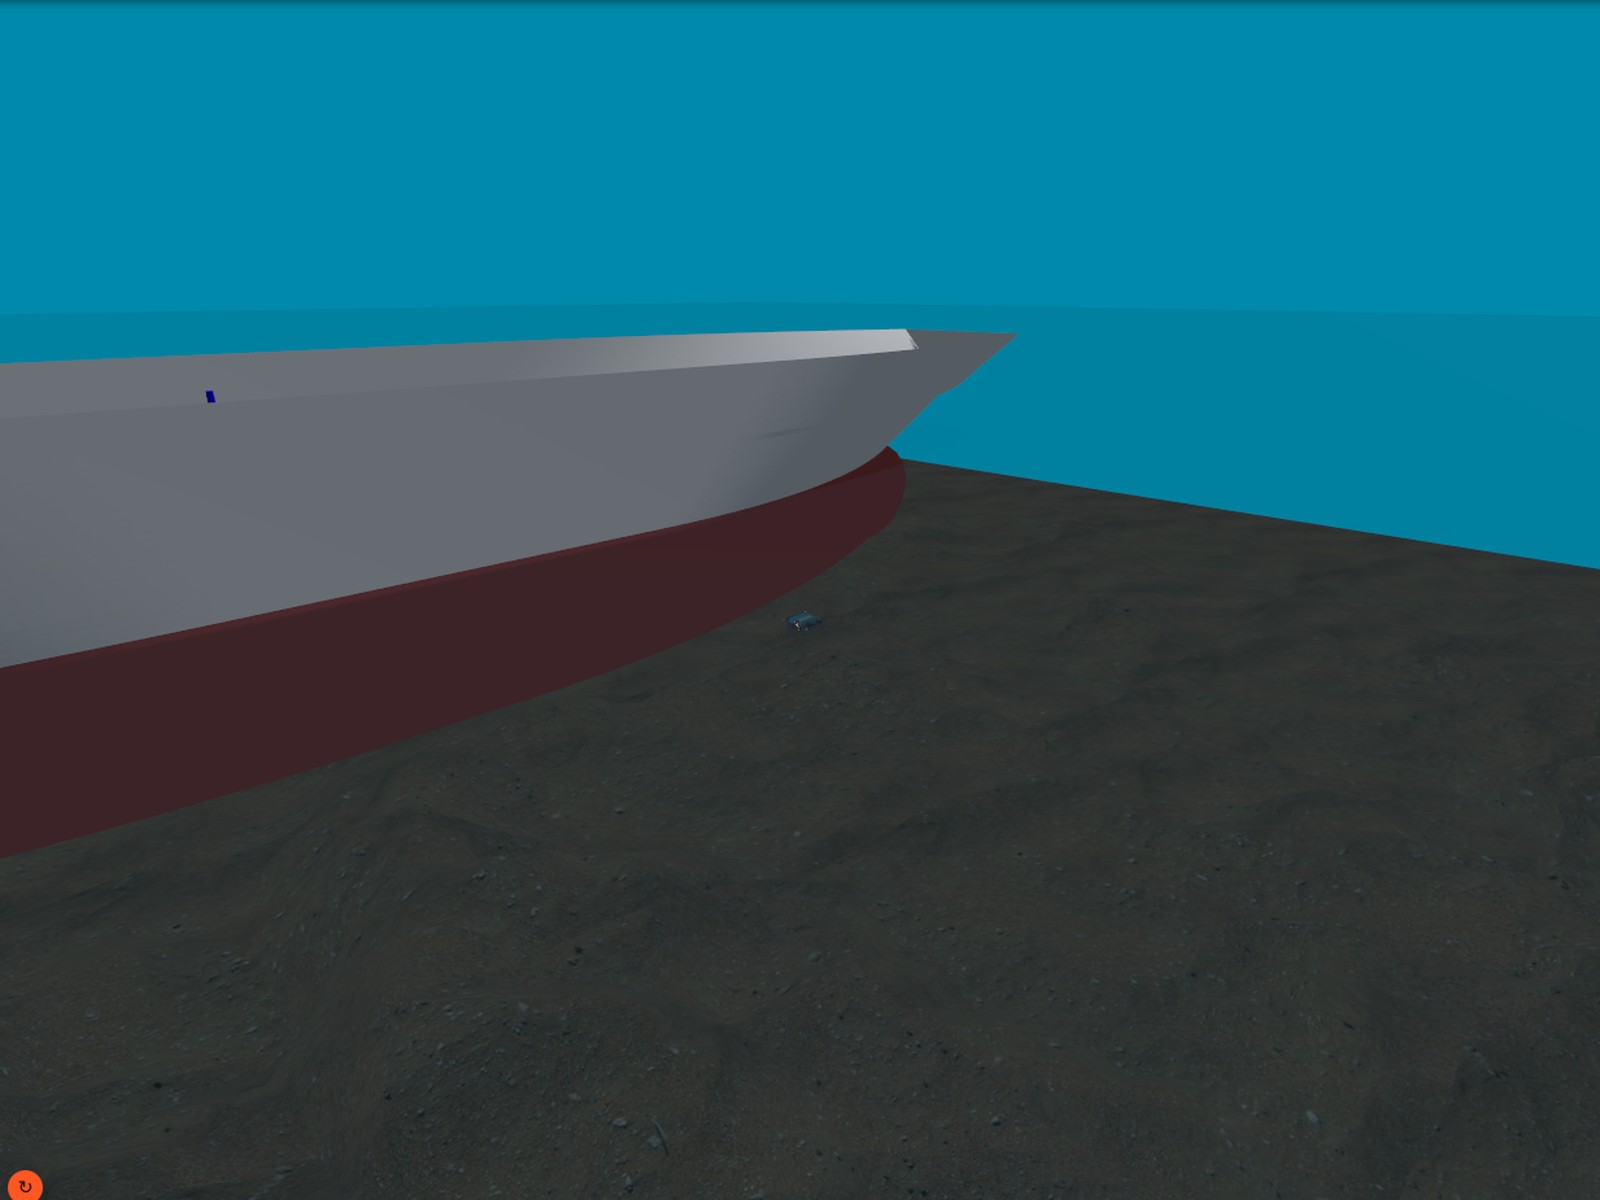
The Charles River Dam crossing rebuilt in Isaac Sim. ArduCopter flies the drone, ArduSub flies the ROV.
Built in one day for challenge R6, safer inspection of critical infrastructure. A Holybro X500 flown by real ArduCopter SITL runs a 37-waypoint mission along the canal walls and under the deck, where the bridge cuts GPS from 12 satellites to 7. Every waterline defect it flags becomes a task for a BlueROV2 Heavy on ArduSub, which dives with GPS off and navigates on a modelled DVL fed into the autopilot's EKF.
Both robots build one model of the structure: 2.96 million lidar points above the water and 1.58 million sonar points below it. The ROV never drifted more than 60 cm over a 200 m dive, and 4 of 4 flagged defects were inspected underwater. The demo is a replay of a recorded 21-topic ROS 2 bag, run live on stage from one Docker launch.
What is modelled and what is real
Real: ArduCopter and ArduSub flight code, MAVLink mission upload, the EKF, ROS 2 Jazzy, RViz2 and QGroundControl. Modelled: the GPS drop under the deck (the bridge lowers the satellite count), the Ouster OS0-128 lidar and 130-degree multibeam sonar as ray casts, murky water as Beer-Lambert attenuation plus silt, and a simulated thermal camera. Thirteen defects were planted as ground truth, nine above the water and four below, including a scour pit with exposed timber piles.
- Result
- 2nd place
- ROV nav error, GPS off
- ≤ 0.60 m
- over a ~200 m dive, 0.16 m at the end
- Combined model
- 4.54 M pts
- lidar above + sonar below
- Defects flagged → inspected
- 4 / 4
- drone hands off to ROV
ArduCopter + ArduSub SITL · MAVLink · Isaac Sim 6 · ROS 2 Jazzy · RViz2 · QGroundControl · Docker · repo